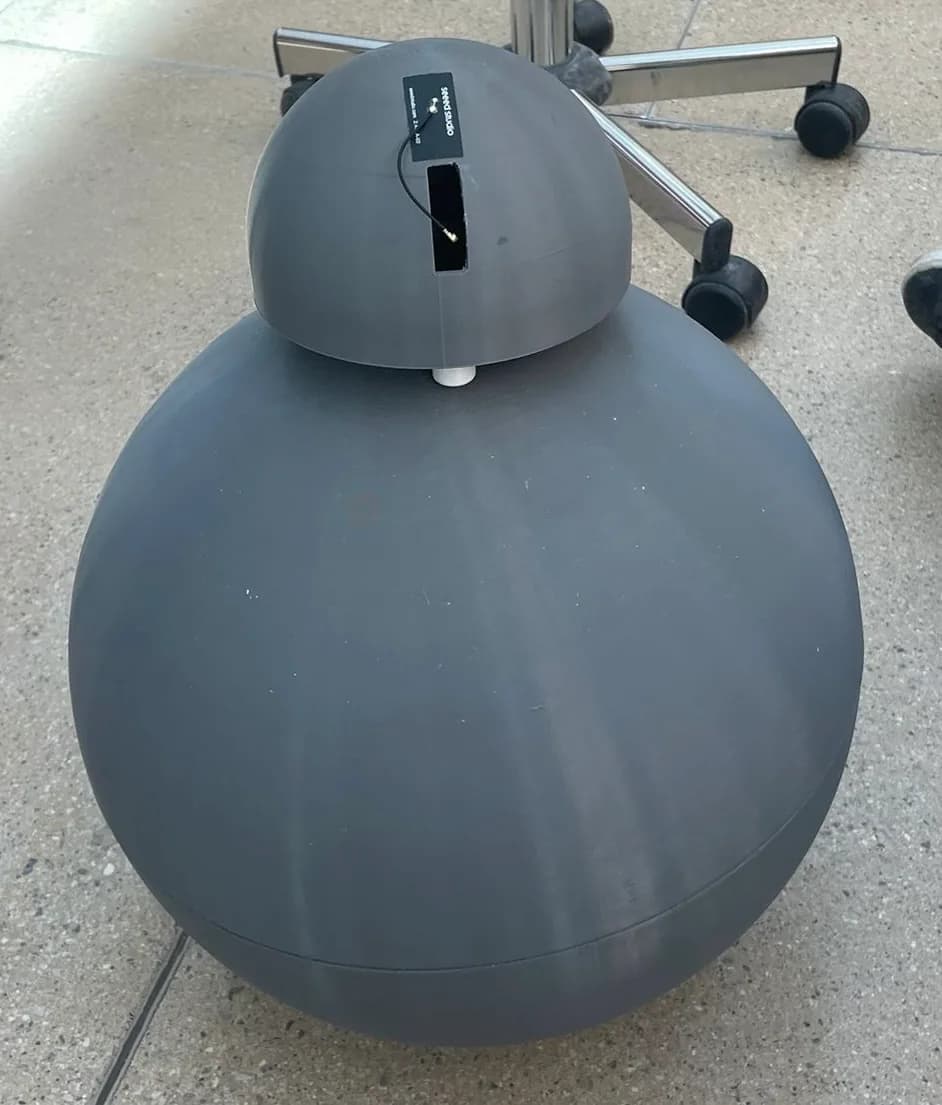
What it is
A self-balancing sphere in the style of BB-8, driven from the inside by a 3-wheel omni-drive.
What I built
I designed the electronics and wrote all the software. That meant deriving the omni-drive inverse kinematics and building a cascaded heading-hold and yaw-rate PID stack with IMU sensor fusion.
The inverse kinematics is a 3x3 mapping of body velocity to per-wheel RPM, with tilt compensation and proportional saturation. Each wheel runs its own PID loop with anti-windup and derivative-on-measurement.
The firmware uses a dual-core FreeRTOS architecture that keeps the Next.js/WebSocket teleoperation stack apart from the control loop. It includes an arm/disarm/kill safety state machine, motor-safe over-the-air updates, and a Python PID-tuning and telemetry toolchain.
The interesting problem
Tuning the PID. It was my first time doing it, and it is kind of an art.